← DROID pilot report · September 20, 2026
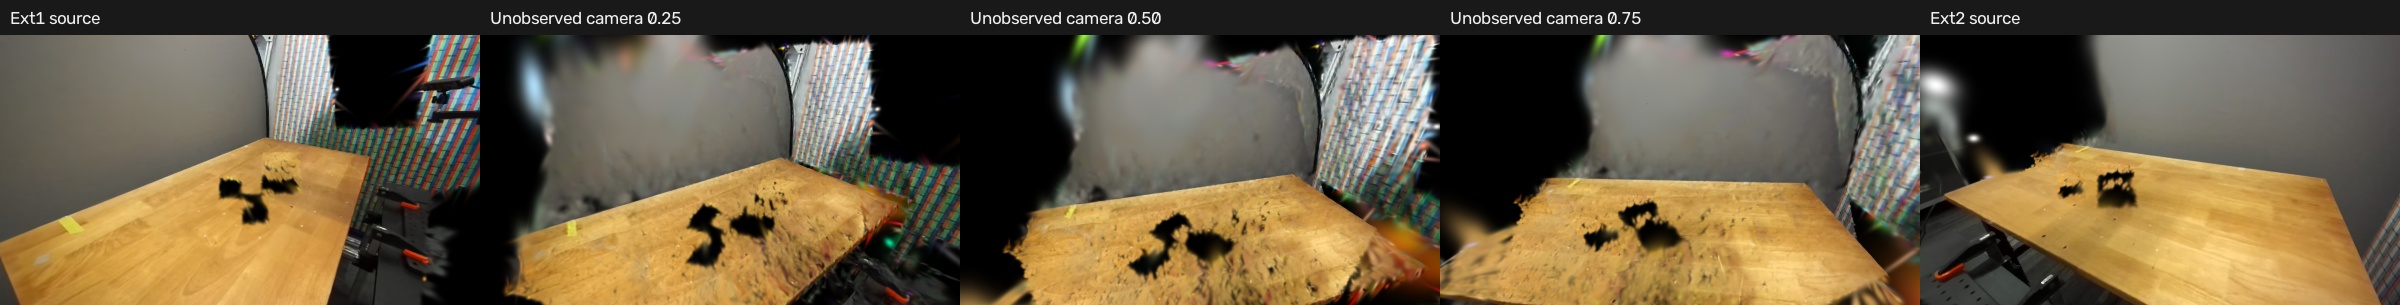
Exactly two external left images train one shared Gaussian field. No wrist or generated images. Right images provide stereo geometry/calibration and RGB evaluation. Ext1 remains the recorded robot-frame anchor.
Held-out rig reprojection: 5.10 → 0.60 px median; 1.35 px p90. Held-out epipolar: 0.51 px median. Landmarks are triangulated for evaluation with all camera poses fixed; held-out tracks never update cameras.
29,912 Gaussians; 4,000 steps; 960 × 540 training images.
Gaussian PLY · Gaussian tensor checkpoint · Matching camera poses · Calibration evidence · Training evidence
| View | Use | Static PSNR (dB) | Static alpha > 0.9 |
|---|---|---|---|
| ext1_left | Training RGB | 40.83 | 88.5% |
| ext1_right | Stereo-side RGB evaluation | 17.86 | 85.2% |
| ext2_left | Training RGB | 22.45 | 87.7% |
| ext2_right | Stereo-side RGB evaluation | 19.68 | 84.0% |
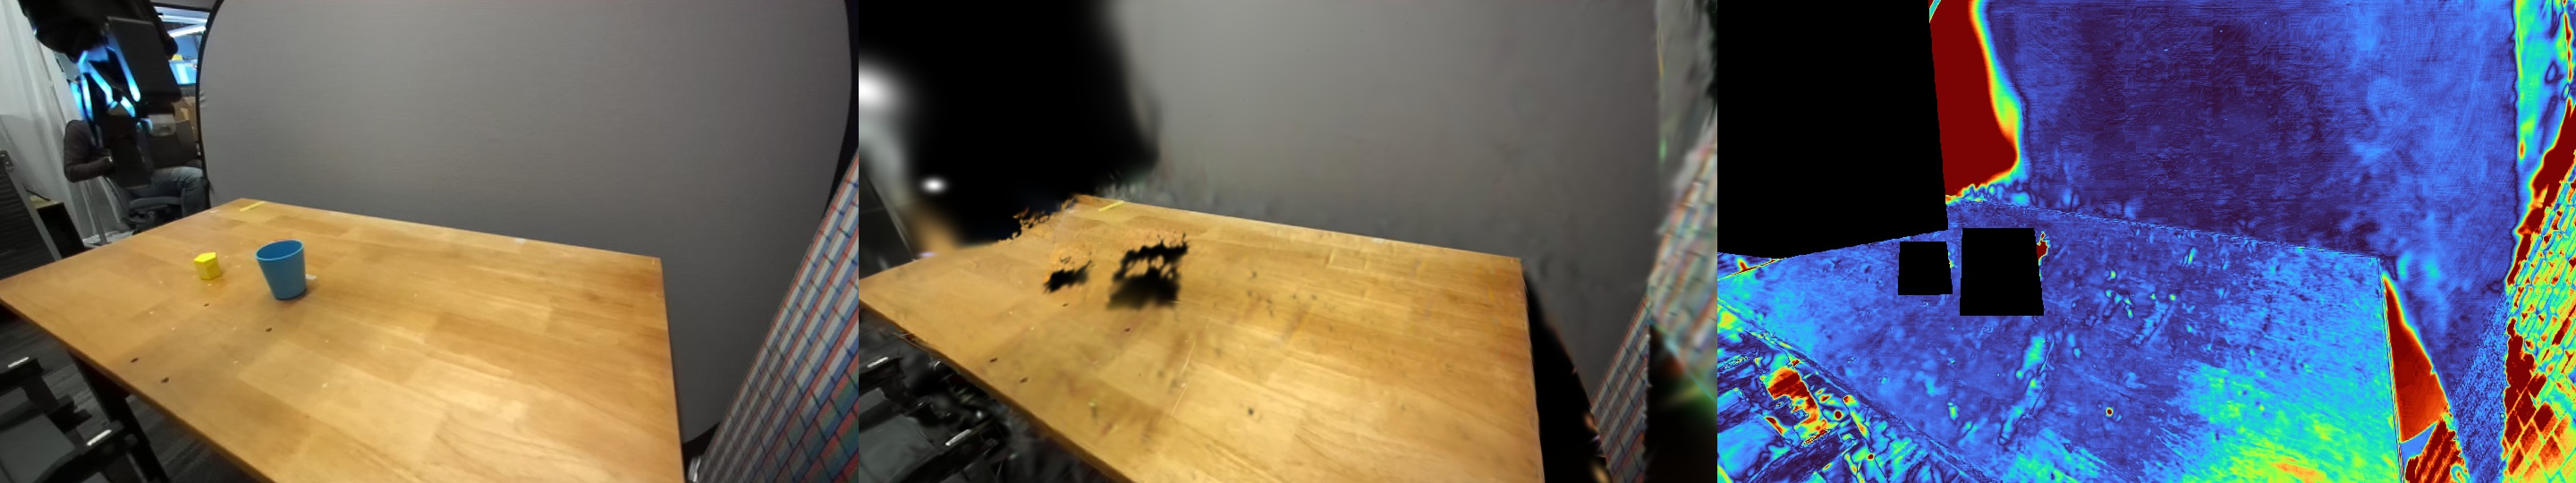
Source-view metrics measure fitting, not independent scene accuracy. Stereo-side appearance is held out of RGB optimization but its stereo geometry is used. Black gaps and intermediate-view artifacts are visible limitations: two images do not observe the surfaces behind every object or the robot. Camera evidence is mostly tabletop features; absolute robot alignment and room-wide geometry need further validation.
Real image | shared-field render | masked absolute error
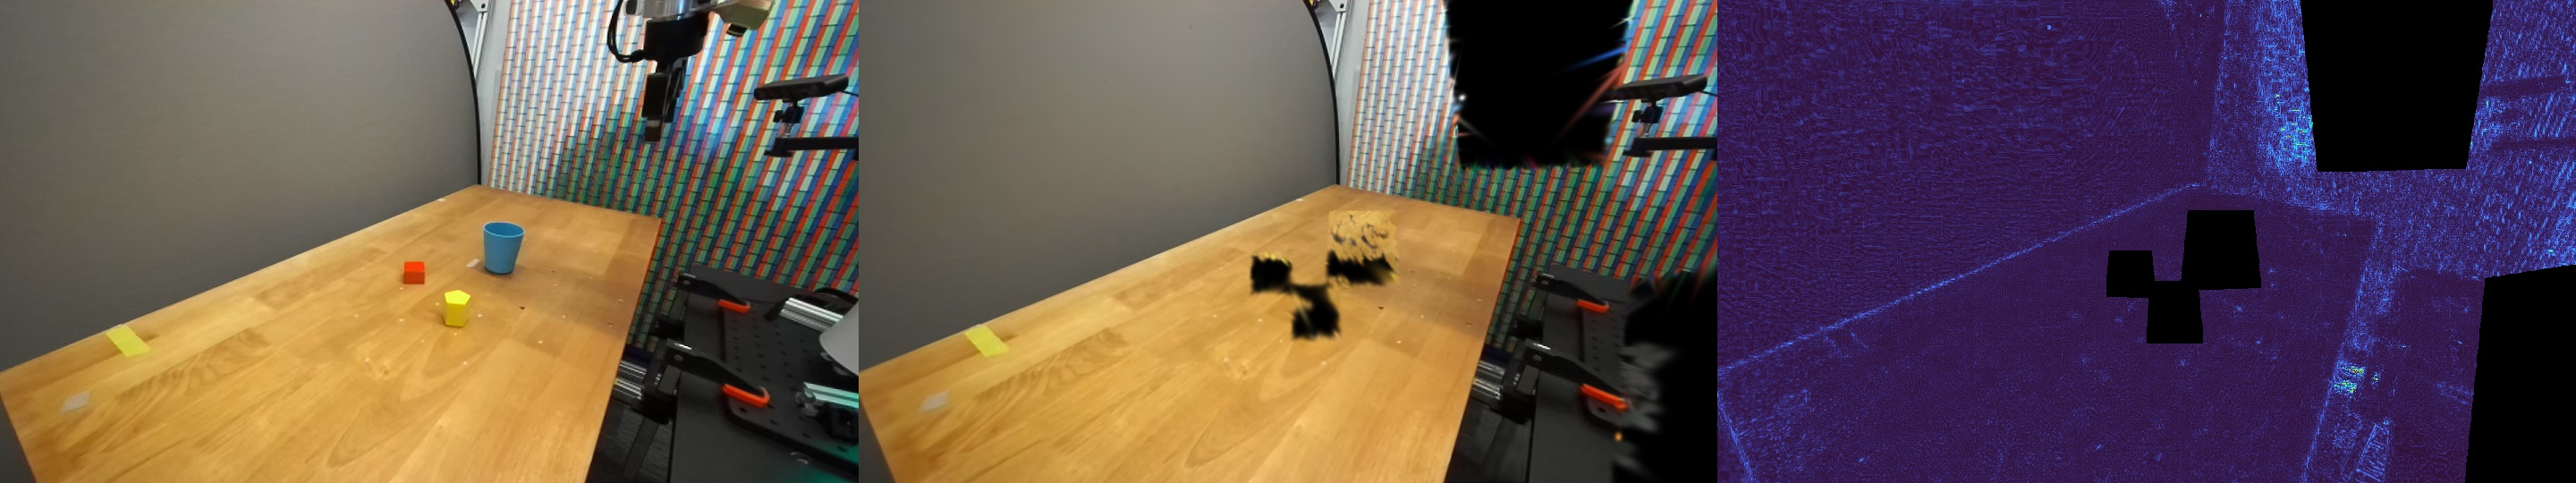
Real image | shared-field render | masked absolute error
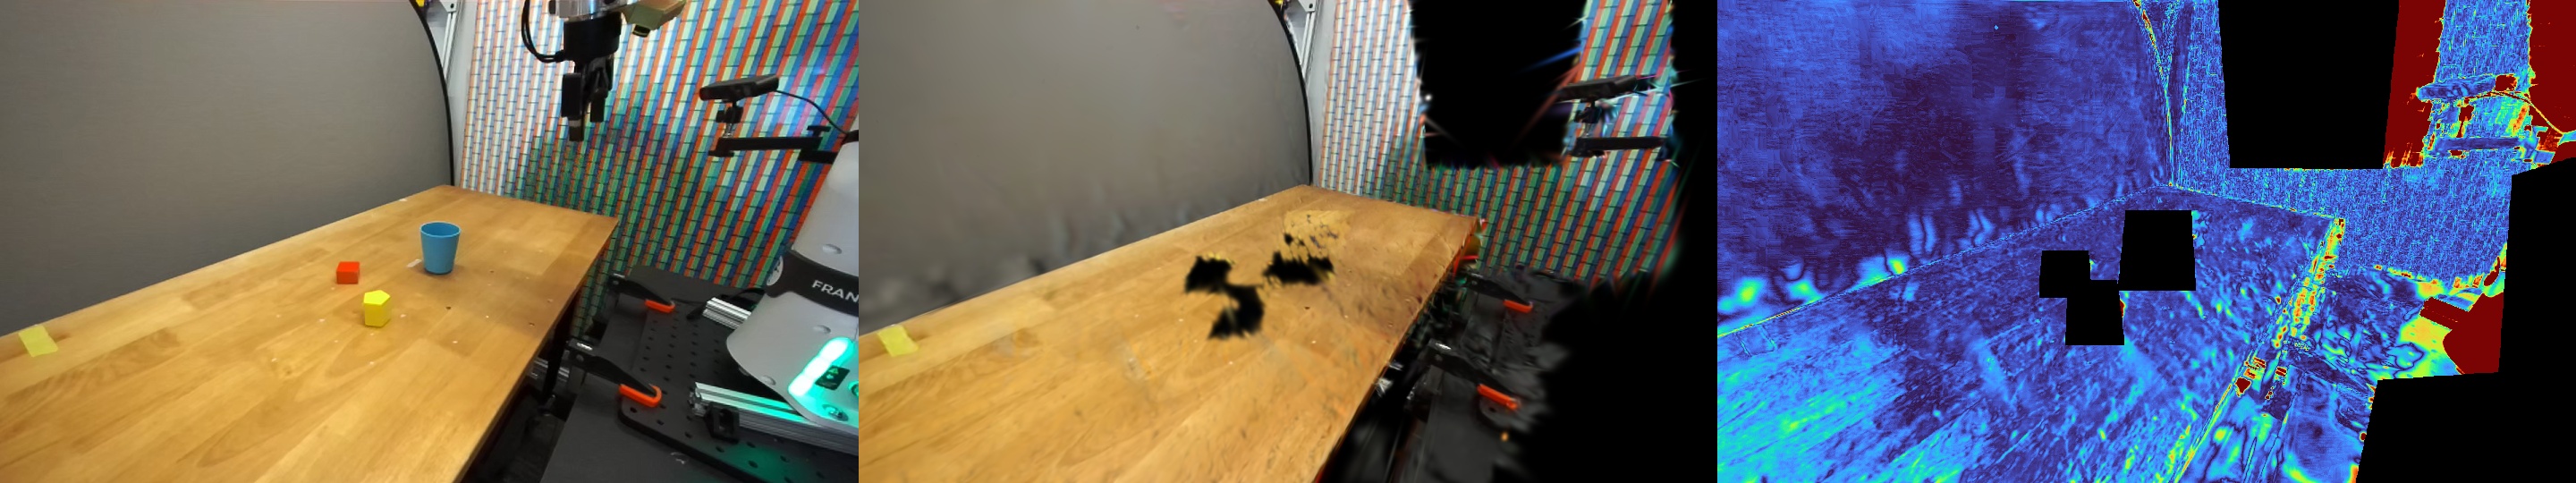
Real image | shared-field render | masked absolute error
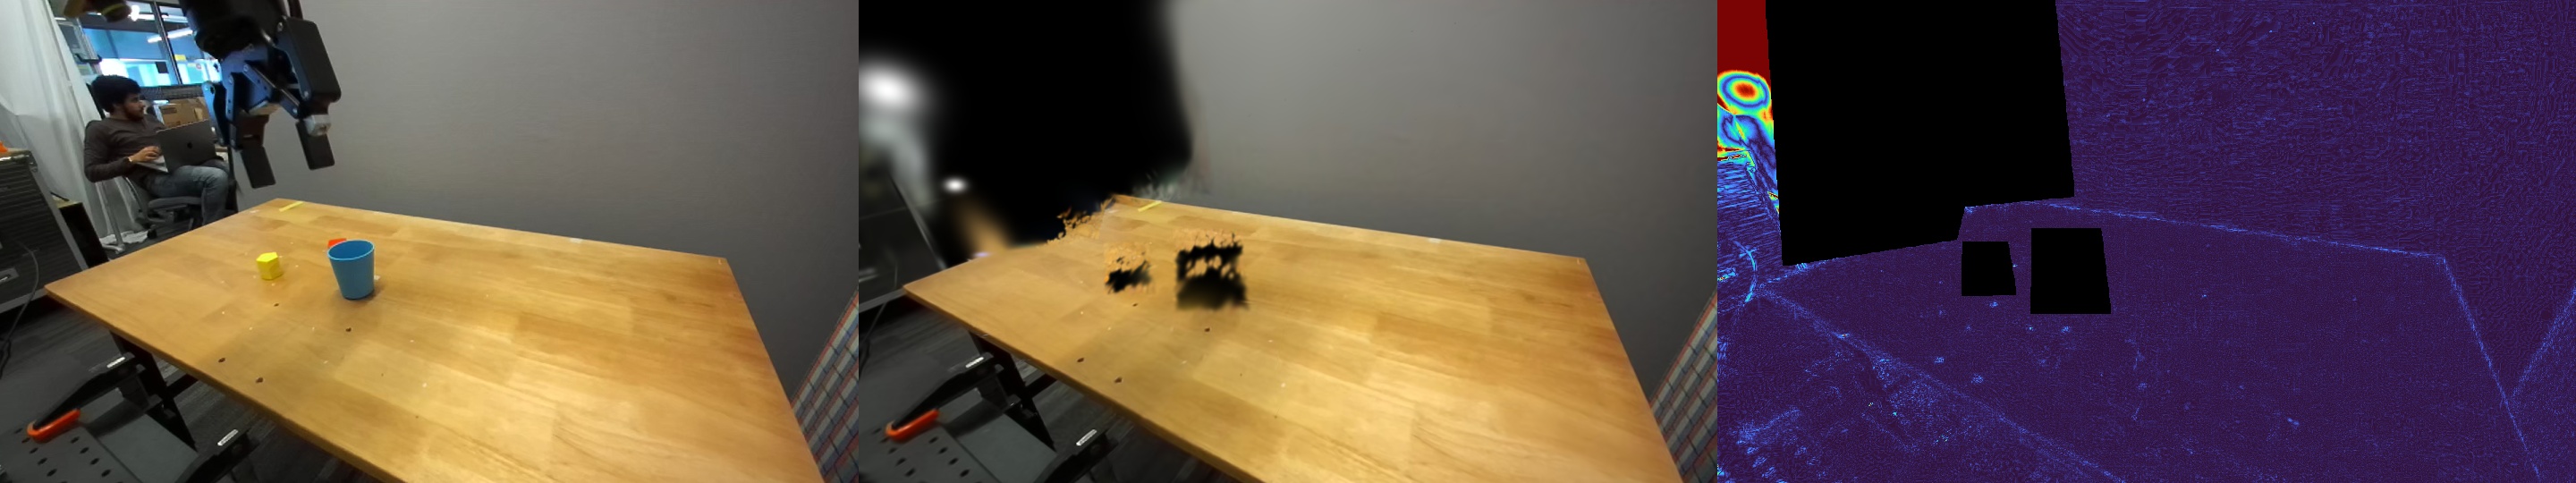
Real image | shared-field render | masked absolute error