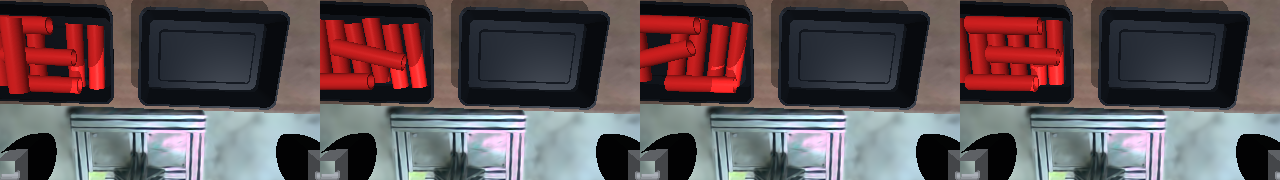
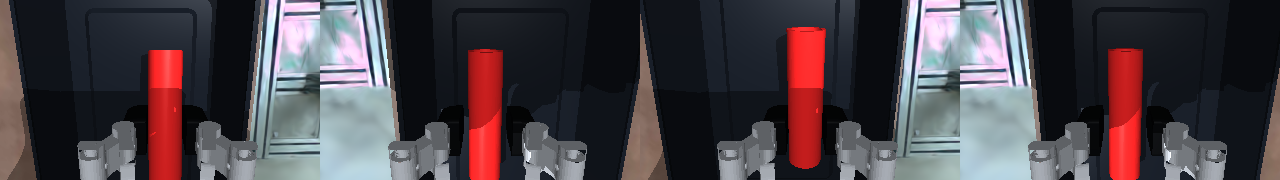
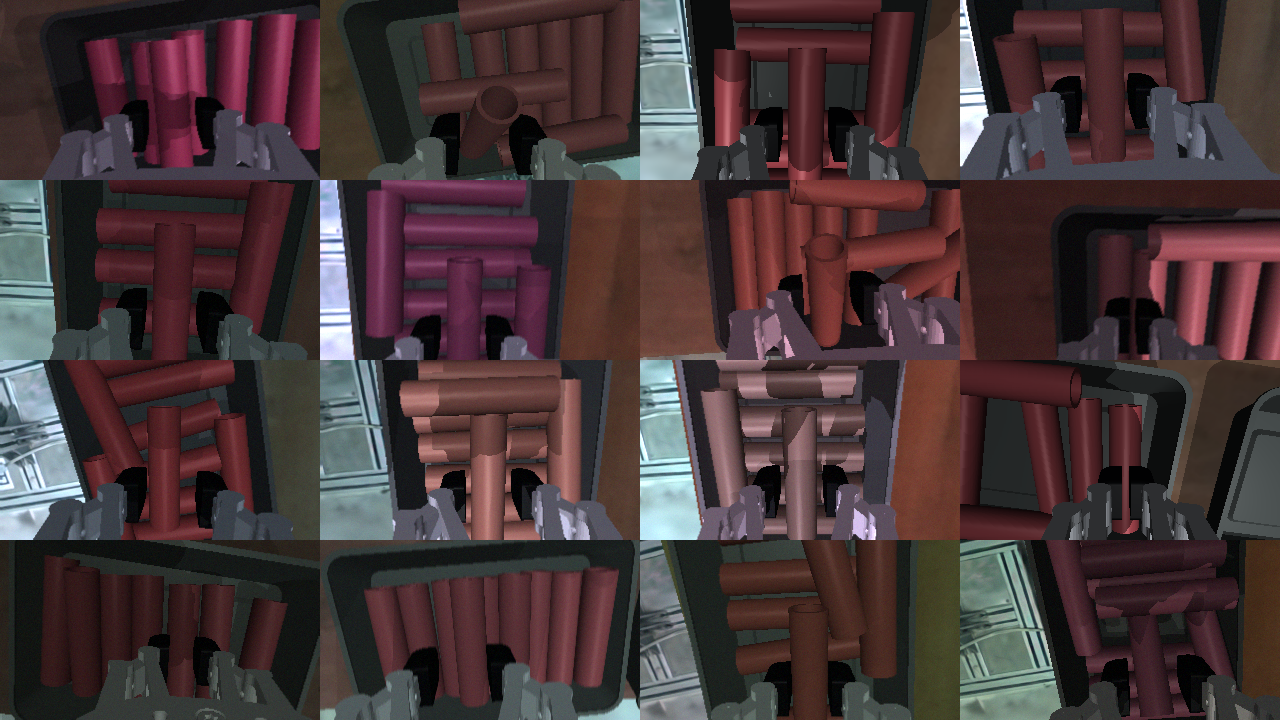
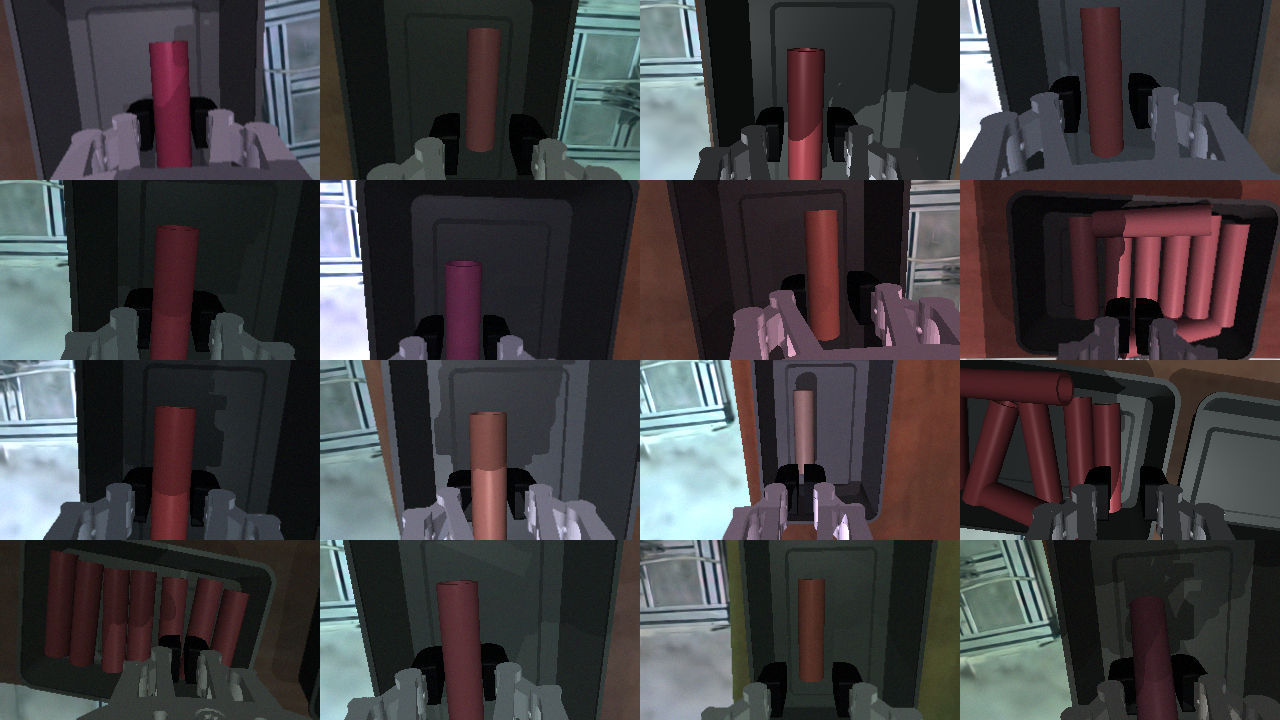
Updated 26 September 2026. Goal: a vision policy that empties a box of 7–10 red tubes on the real UR5 + RG2 using only the wrist
Intel RealSense D415 image and the robot state. The privileged scripted expert collects demonstrations in simulation under domain randomization,
an ACT policy is trained on wrist RGB + 16 robot-state values, evaluated in simulation against the expert on the same starts, and exported as a bundle for the robot.
Now: Robot and observation changes (user decisions, 26 Sep): EE = closed-fingertip midpoint, 17-value state with fingertip gap and lift, D415 optical centre on the front glass, robot rotated 180° with home shoulder pan 0. First expert episodes with the new setup are below.
1. Setup and domain randomization
done 2026-09-24 D415 on mount v4, 320×180 policy image, DR in four ablatable groups. Found and fixed: overlapping box spawns, pile towers that ejected tubes, idle-arm drift from gain DR. Stability numbers below are from the final configuration.
Wrist camera: D415 on mount v4
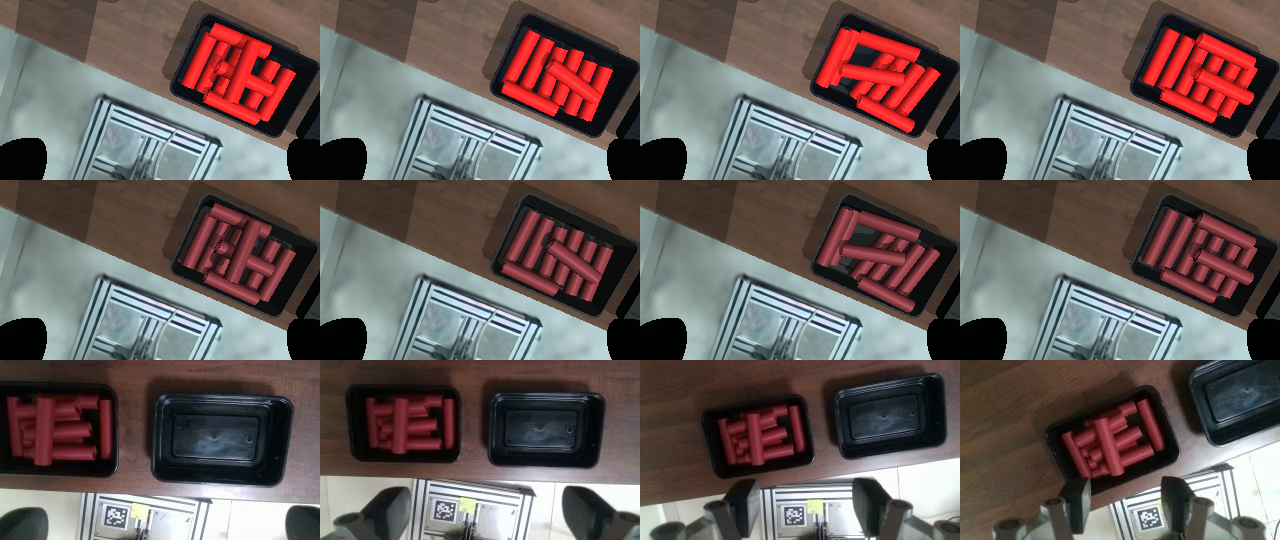
Sim D415 policy image (320×180), nominal, start poseSame worlds during the expert's picks (240 control steps in)Rows: sim before calibration, sim after calibration, real D415 wrist footage of the rig (user's video, 26 Sep). Median colour real vs calibrated sim: tubes (130,56,63) vs (138,59,66), table (79,61,49) vs (83,64,51); boxes set by eye to black with a little gloss.
Real camera
Intel RealSense D415 on mount v4 (user-approved pose; hand-eye not measured)
Real stream
1280×720 RGB at 30 fps (user's choice)
Intrinsics (factory)
fx 913.9, fy 912.1, cx 644.2, cy 347.9 px; distortion coefficients all zero
Policy image
320×180 RGB: the 1280×720 frame area-averaged 4×4 (no crop), then a JPEG q85 round trip, identical to the stored training frames
Sim render
320×180 directly, D415 intrinsics scaled by 1/4; D455 removed; mount coloured blue
Real D415 frame comparison
done 26 Sep with the user's wrist video: colours and lighting calibrated (see image)
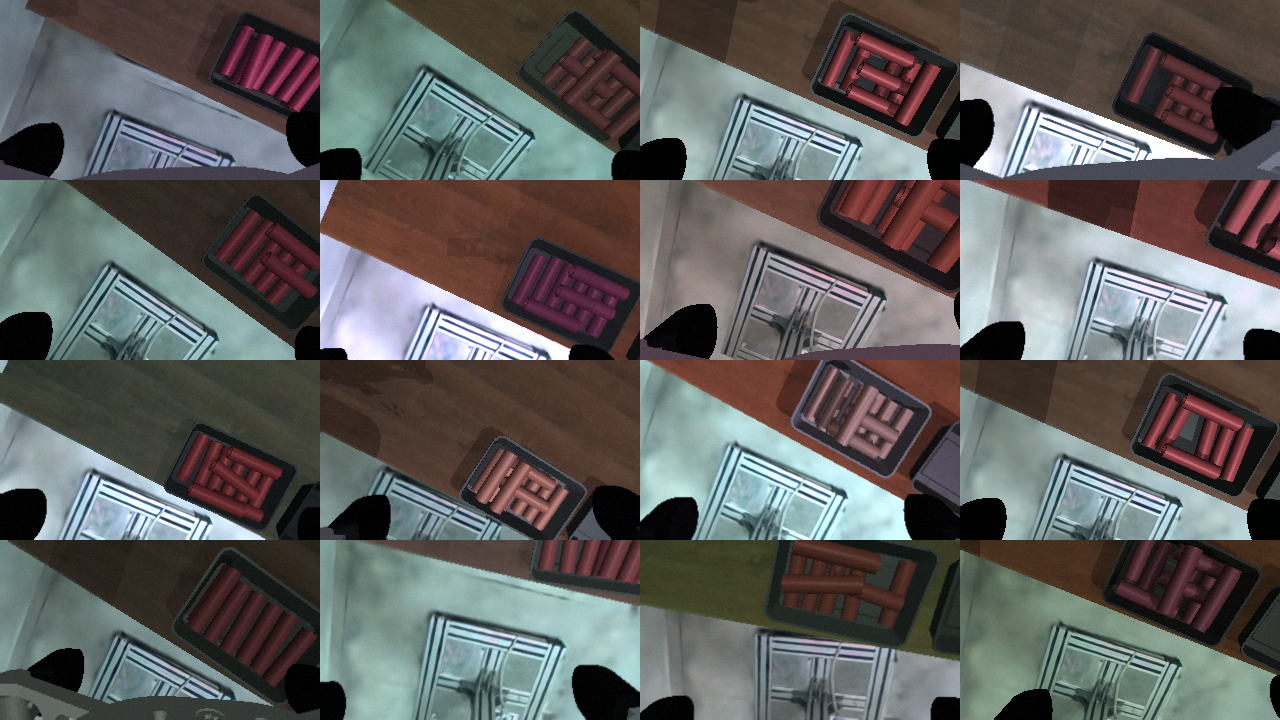
Gains are multipliers; distances in metres, angles in degrees; ranges are the full range at DR scale 1 (10% of worlds are nominal). A disabled group keeps all random draws, so ablations use identical starts.
Group
Field
Range
layout (always on)
tube_count
[7, 10]
layout (always on)
rows_fraction
0.5
layout (always on)
table_xy_m
0.03
layout (always on)
table_yaw_deg
3.0
layout (always on)
basket_xy_m
0.01
layout (always on)
basket_yaw_deg
5.0
layout (always on)
robot_xy_m
0.01
layout (always on)
robot_yaw_deg
1.5
layout (always on)
initial_joint_deg
[6.0, 4.0, 5.0, 6.0, 5.0, 12.0]
layout (always on)
initial_gripper_open_min
0.85
camera
camera_xyz_m
0.01
camera
camera_rotation_deg
5.0
camera
camera_focal_fraction
0.03
camera
camera_principal_px
[12.0, 12.0]
camera
lens_k1
0.03
camera
motion_blur_px
3.0
camera
motion_blur_prob
0.3
camera
stale_frame_prob
0.05
appearance
light_gain
[0.6, 1.6]
appearance
light_tint
[0.88, 1.12]
appearance
light_ambient_max
0.12
appearance
light_pos_m
0.8
appearance
light_dir_deg
35.0
appearance
light_shadow_prob
0.8
appearance
specular_gain
[0.5, 1.5]
appearance
material_gain
[0.9, 1.1]
appearance
box_colour_gain
[0.7, 1.5]
appearance
table_colour_gain
[0.8, 1.25]
appearance
table_tint
[0.92, 1.08]
appearance
table_saturation
[0.5, 2.2]
appearance
tube_colour_shade
[0.85, 1.3]
appearance
tube_saturation
[0.6, 1.05]
appearance
background_gain
[0.7, 1.3]
appearance
background_tint
[0.95, 1.05]
appearance
exposure_gain
[0.75, 1.25]
appearance
white_balance
[0.92, 1.08]
appearance
image_noise_std_255
3.0
physics
tube_mass_scale
[0.8, 1.25]
physics
box_mass_scale
[0.8, 1.25]
physics
friction_scale
[0.7, 1.3]
physics
friction_per_object
True
physics
gripper_force_scale
[0.8, 1.2]
physics
gripper_kp_scale
[0.8, 1.2]
physics
arm_kp_scale
[0.85, 1.15]
physics
joint_damping_scale
[0.8, 1.2]
control
action_delay_steps
[0, 0]
control
action_noise_std
0.05
control
state_noise_joint_rad
0.0005
control
state_noise_width
0.0005
control
state_noise_tcp_m
0.0005
control
state_noise_rot
0.002
Stability checks under the new DR
Pile settling, binpick-dr-7
12/32 settled in 5 s; 0 tubes left the box; 0 non-finite; peak penetration 0.09 mm
Pile settling, binpick-dr-8
9/32 settled in 5 s; 0 tubes left the box; 0 non-finite; peak penetration 0.49 mm
Pile settling, binpick-dr-9
5/32 settled in 5 s; 0 tubes left the box; 0 non-finite; peak penetration 0.43 mm
Pile settling, binpick-dr-10
2/32 settled in 5 s; 1 tubes left the box; 0 non-finite; peak penetration 0.37 mm
Pile settling, binpick-nominal-10
5/32 settled in 5 s; 1 tubes left the box; 0 non-finite; peak penetration 0.41 mm
Resting boxes, 10 tubes, 50 s, full DR
0/192 boxes toppled; max box rise 0.17 mm
Expert running, [7, 10] tubes, 120 s, full DR
0/64 worlds non-finite; 0 boxes toppled in 0 worlds
Sim 320×180 render vs 1280×720 render area-averaged 4×4 (the real pipeline)
mean abs difference 4.9–5.7/255 over 24 frames at full DR (states match to 30 mm; edge energy within 1.5%)
2. Data collection
done 2026-09-25 2-box demonstrations: 413 accepted episodes (D 174, E 239; expert 91-92% picked, 51-53% cleared per run). DAgger round 0 (policy-driven states labelled by the expert) started and stopped with partial data.
Two boxes since 25 September: a policy trained on the 3-box data sent 29% of carries to the wrong box, because the expert alternated between the left and right boxes, which the wrist camera cannot show at grasp time. The source box (centre) and all DR are unchanged; the left box is removed and every tube goes to the right box. The expert baseline below is the 2-box one; the ablation table and the first dataset rows are from the 3-box task.
Expert baseline on 7–10 tubes
992/1120 tubes picked (88.6%, bootstrap 95% CI 85.9%–91.0%); fully cleared 56/128 (44%, Wilson 95% CI 35%–52%); valid 79/128 (reasons {'tube_penetration': 42, 'actuator_force': 5, 'box_penetration': 8, 'joint_speed': 3, 'box_toppled': 1}); non-finite 0; time cap 60 s + 45 s per tube.
Stand (pedestal) turned 90° about z; action noise now smooth (gripper no longer jitters: direction reversals in slow motion 37% -> 10%); camera near plane 2 mm so the finger linkage close to the D415 is drawn instead of see-through. 8 tubes, 1 placed in 20 s.
Scripted expert with the new robot setup (26 September)
8 tubes (messy pile): 7 picked and placed in the right box in 98 s, valid. EE = closed-fingertip midpoint, robot base rotated 180° with home shoulder pan 0, D415 optical centre on the front glass.
3-box task (paired with the 3-box baseline, 91.5% picked). One DR group switched off at a time; every random draw is kept, so the piles are identical to the full-DR run on those starts.
Run
Tubes picked
Cleared
Full DR on the same starts
No DR at all
538/566 (95.1%)
50/64
524/566 (92.6%), cleared 31/64
Physics DR off
512/566 (90.5%)
35/64
524/566 (92.6%), cleared 31/64
Control DR off (action and state noise)
543/565 (96.1%)
49/64
524/566 (92.6%), cleared 31/64
Camera DR off
516/566 (91.2%)
33/64
524/566 (92.6%), cleared 31/64
Appearance DR off
514/565 (91.0%)
31/64
524/566 (92.6%), cleared 31/64
Full DR + action delay 0–2 steps
335/566 (59.2%)
21/64
524/566 (92.6%), cleared 31/64
Demonstration dataset
Accepted = at least 80% of the tubes picked and valid (box contacts ≤ 2 mm). Rejections so far: {'invalid': 528, 'picked fraction below 0.8': 128}. Frames are 320×180 JPEG q85 wrist images with the 16-value state and the expert's 7-value action.
Run
Accepted/finished
Frames
JPEG size
3-box pilot (seed 2000, not used)
40/64
139,623
1.6 GB
3-box A (seed 3000, not used)
99/167
300,601
3.2 GB
3-box B (seed 4000, not used)
185/300
598,384
6.6 GB
3-box C (seed 5000, not used)
188/300
625,880
6.9 GB
2-box D (seed 6000, running)
174/300
599,605
6.6 GB
2-box E (seed 7000, running)
239/450
804,575
8.9 GB
Total
925/1581
3,068,668
33.7 GB
Pilot check, end to end
An ACT model trained for 6,000 steps on the 40 pilot episodes (validation action L1 0.076) was exported, verified and evaluated in the simulator on 32 paired starts. As expected at this data size it does not solve the task: it approaches and grasps but carries the tube away from the boxes. Measured: bundle delivered 0/283 tubes in 150 s episodes; 6 episodes toppled a box. Pipeline: dataset → training → export → verified bundle → simulator evaluation loading only the bundle.
in progress 2026-09-25 v2 = D+E, 100k steps, validation action L1 0.055 (preliminary D-only model: 0.061 at 40k).
4. Sim evaluation
in progress 2026-09-25 v2 on the first 32 expert-baseline starts: picked 50/283 (17.7%, CI 12.3–24.2) vs 37/283 for the D-only model and 88.6% for the expert on the same starts; delivered 27/283; 4 box topples; 1/32 cleared. Full stage-4 evaluation (ablations) not yet run.
Picked 50/283 tubes (17.7%) on 32 paired starts; lifts 1.69 per episode. In this episode it delivers 4 of 7 tubes in about 3 minutes, then drifts up and out of the workspace with 3 tubes left.
The ACT policy is far below the expert: v2 picks 17.7% of tubes vs 88.6% (same 32 starts). Offline it imitates every phase closely, so this is closed-loop drift into states the demonstrations do not cover (coverage problem / covariate shift): it freezes above the pile or drifts out of the workspace when few tubes are left. Planned fix: DAgger rounds.
The scripted expert cannot work with action delay: at 2 steps (100 ms) it picks 4% of tubes in 150 s. Demonstrations are collected without delay; delay is only used to test the policy.
Action noise (σ 0.05 of a step) costs the expert: 92.6% picked and 31/64 bins cleared with it vs 96.1% and 49/64 without, on the same starts. It is kept in the demonstrations on purpose (recovery states for imitation).
About half of the expert's episodes fail the validity gate, mostly tube–tube penetration above 1.5 mm (40 of 128); those episodes are rejected from the dataset.
Resting tube piles creep: in 10–20% of worlds a tube still moves 1–3 cm/s after 15 s (CG-80, CG-200 and MuJoCo-Newton behave the same), so the strict 5 s settling audit passes only 2–12 of 32 worlds per case. No ejections, NaN or penetration above 0.6 mm; the expert waits at most 6 s.
Tube size is not randomized: the visual mesh cannot be scaled per world.
Sim renders the 320×180 image directly while the real image is a 4×4 area average: measured mean difference 4.9–5.7/255 at full DR; training adds blur augmentation.
The real RG2 width mapping, TCP offset relative to the real flange, camera latency and hand-eye calibration are not measured; the control contract leaves them null.
Fixed in stage 1: box pose DR of ±20 mm/±8° let neighbouring boxes spawn overlapping (5/192 toppled); loose 7–10 tube drops towered and ejected tubes; arm gain DR with nominal gravity compensation let an idle arm drift up to 0.2 m in 30 s.