UR5 v90 bottle policy · real-robot runs · 26 October 2026
All 29 runs of the RGB-only v90 policy on the real UR5/RG2, each as one synchronized wrist + external video, with policy details, simulation vs real success rates, and charts. Filter by outcome, bottle pose, whether the bottle is in the first frame, and action scale.
Open the run gallery →UR5 force-mode profiling · 15 October 2026
Five stiffness/damping settings on the same XYZ reference: target and actual paths, tracking error, jerk, velocity spectra and free-rotation drift. Includes raw recordings and comparison limitations.
Open the force-mode profiling report →UR5 controller profiling · 14 October 2026
Interactive joint and end-effector tracking graphs, gain/lookahead comparisons, fitted response models and raw measurements.
Open the profiling report → · Watch today’s 11 recordings →Recording inspector · real robot & simulation
Explore a bottle-picking policy run on the real UR5/RG2 and a simulated expert episode. Replay the robot in 3D, inspect synchronized camera images and observations, compare action chunks with measured motion, and follow the interactive execution guide.
Open the interactive recording viewer →Videos · real-robot bottle picking
7 October 2026: two successful picks and one failed attempt, with external and wrist camera views.
Watch the selected attempts →Tube task: inside the observation-based scripted expert
Interactive input-to-output diagrams of the wrist-camera expert: SAM3 and FoundationStereo, every FSM branch, grasp and release feedback, recovery, and the shared NN/scripted robot controller. Compare the previous real-run policy with the deployed two-tube placement correction.
Explore the scripted expert: flowcharts, conditions and data flow →Teleoperated survey robots under $5,000
18 indoor wheeled camera robots that can be driven remotely over the internet: consumer, telepresence, developer/ROS and 4G rovers. Verified US prices, buy links, images, and a filterable comparison of camera, connectivity, remote access, battery and auto-docking, sorted cheapest first.
View the robot comparison →Lab geometry: three models, two phones
MapAnything, Depth Anything 3, and VGGT-Omega on both complete lab recordings. Six colored point clouds, 128 keyframes per video, camera paths, and downloadable PLY files.
Explore the point-cloud comparison →Splat gallery: fly through the scenes yourself
Five trained splats (the phone walk of the lab, the 58-, 47- and 8-view RealSense captures) in one page. Pick one, then orbit or fly the camera; your own browser does the rendering. Each is a 30–60 MB download.
Open the splat gallery →Lab splat from a phone video
One 103-second handheld phone walk around the lab turned into a 3D Gaussian splat: 775 frames, all with camera poses, 865k gaussians. Includes a walk-through video, an overhead video and the pose fix that made it work.
View the lab splat →DROID videos → MuJoCo + Gaussian scenes
Fused ext1/ext2 Gaussian backgrounds, three-camera real/sim comparisons, a complete 360° scene flythrough, contact-driven simulation, and transfer tests on three DROID episodes from different labs. Includes synchronized external/wrist videos, SAM 3D assets, and a runnable scene package.
View DROID reconstruction →superdex_gs simulator
SuperDex contact physics with the calibrated Gaussian-splat D415 wrist camera for the UR5/RG2 bottle pick: physics validation, domain randomization, throughput and GPU benchmarks, videos.
View superdex_gs →Physics-only YAM bottle picking
SuperDex pick and release, ComFree contact diagnostics, and MuJoCo/MJWarp reference comparisons. Videos, trajectories, and measured results.
View simulator experiments →RL teacher → visual student
State RL teacher training, visual student learning, and unfiltered simulation evaluations.
View RL teacher → visual student →MJLab Gaussian simulator
Canonical standalone tasks for BC, RL, evaluation and browser visualization.
View MJLab Gaussian simulator →GSim simulator benchmarks
Parallel Gaussian rendering, GPU simulation, visual correctness, and memory measurements.
View GSim benchmarks →Phase 1: bottle-picking policy
Three demonstration episodes, eight ACT rollouts, training curves and full evaluation results. Final combined-DR success: 90/100; isolated conditions: 5–8/10.
View videos and training results →Latest real2sim experiments
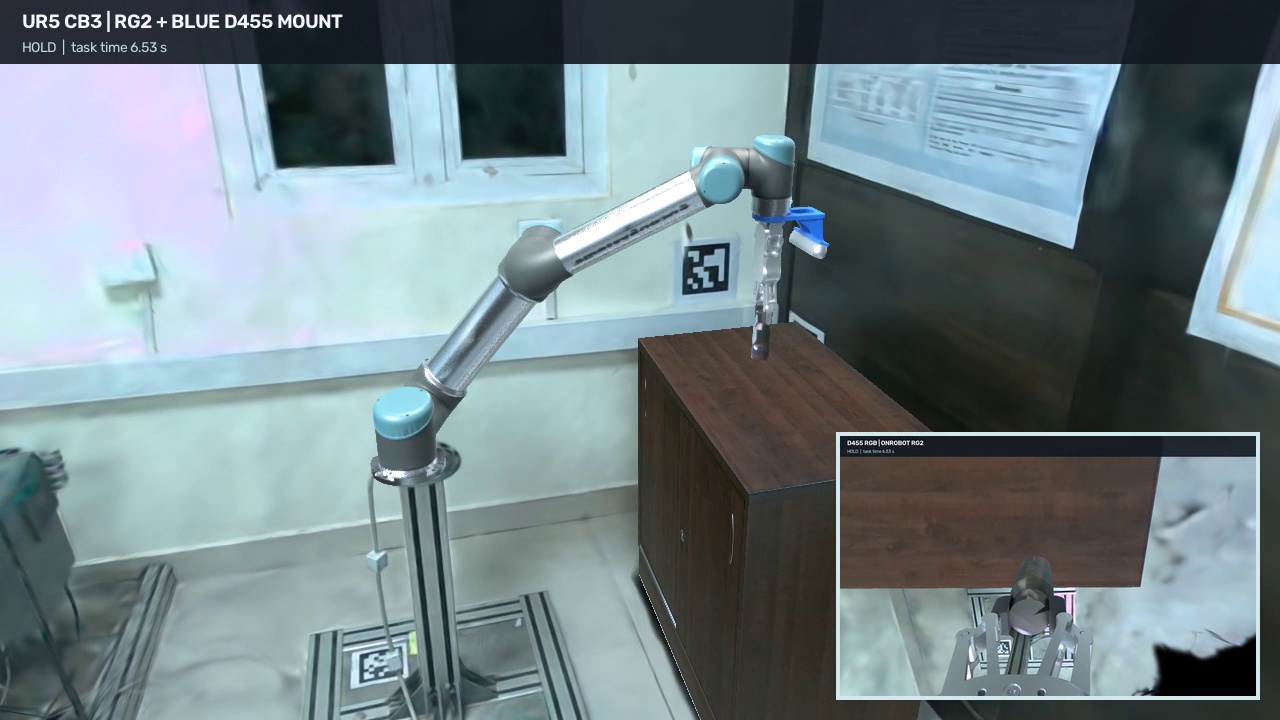
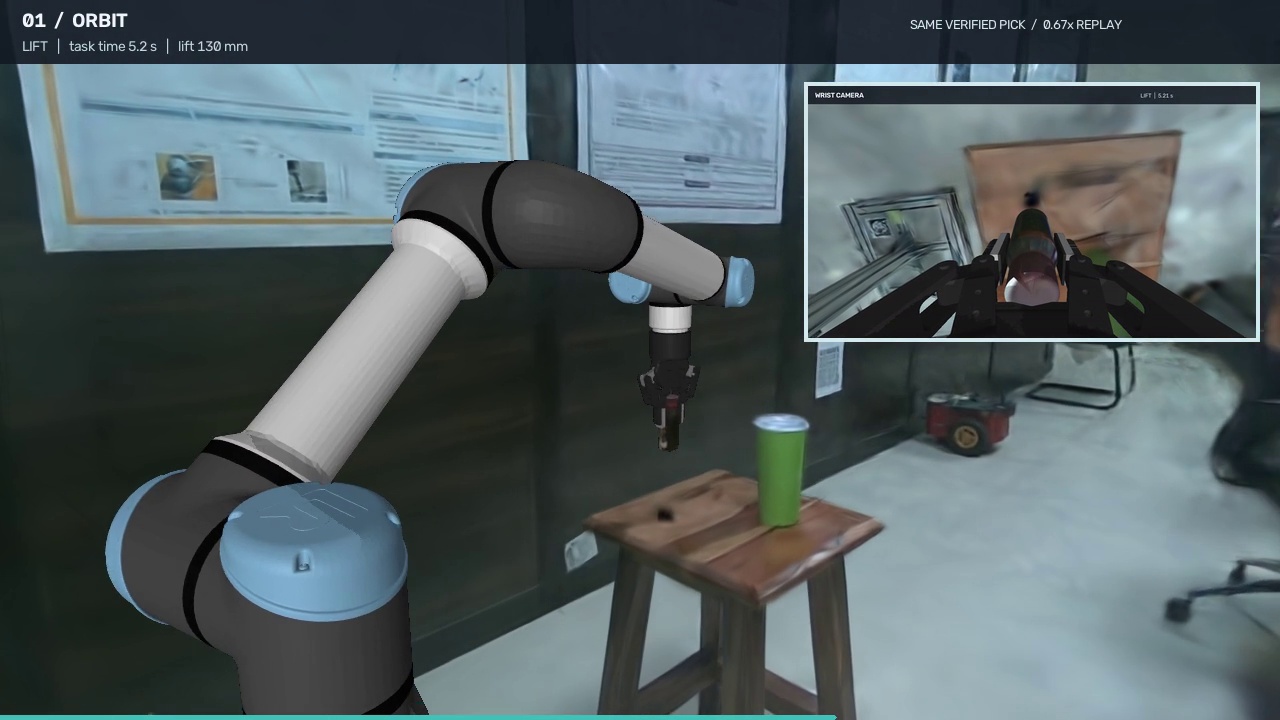
Selected videos, renders and verification results from the two latest experiments. Each report uses its own capture and evaluation setup; scores are not directly comparable across experiments.
How this works
90 seconds, end to end: 58 photographs, camera poses, metric depth, segmentation, then two branches — the background reconstructed as 3D Gaussians with the objects carved out, and the objects rebuilt as meshes — recombined in MuJoCo. Every 3D frame is real pipeline output; every number on screen is measured.
Captures
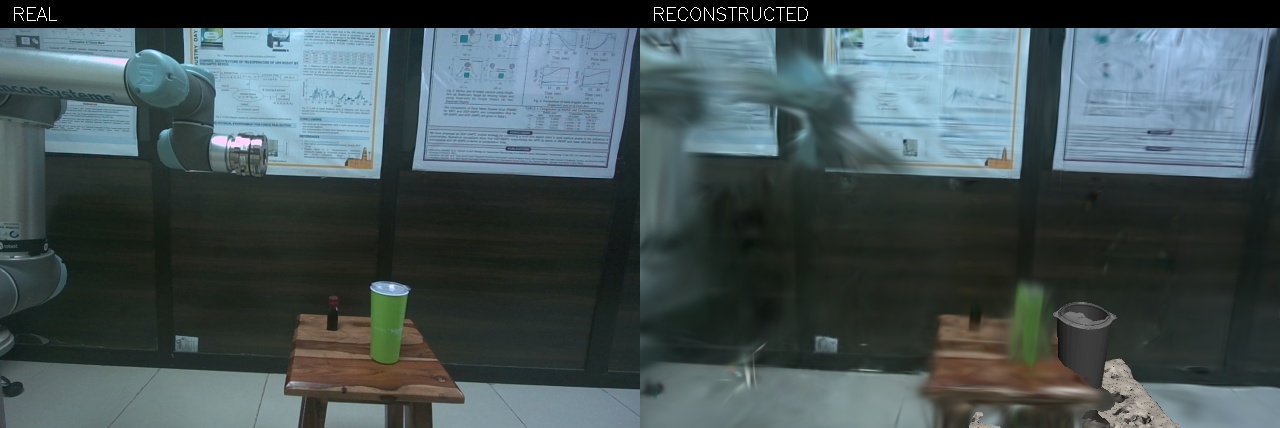
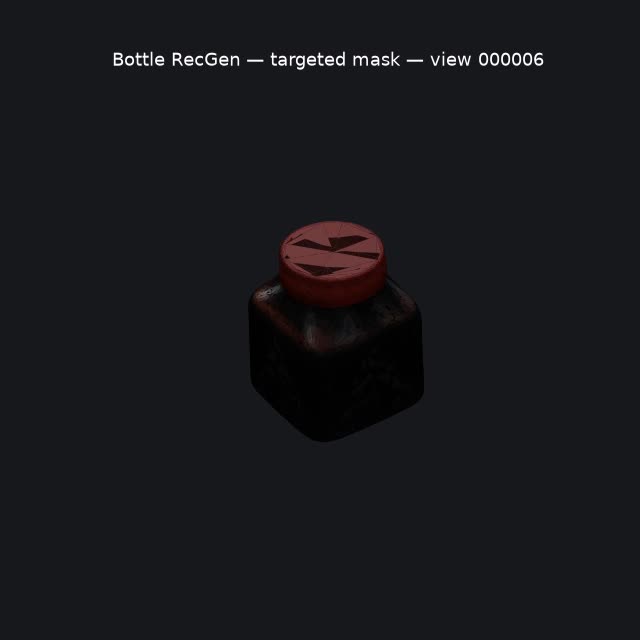
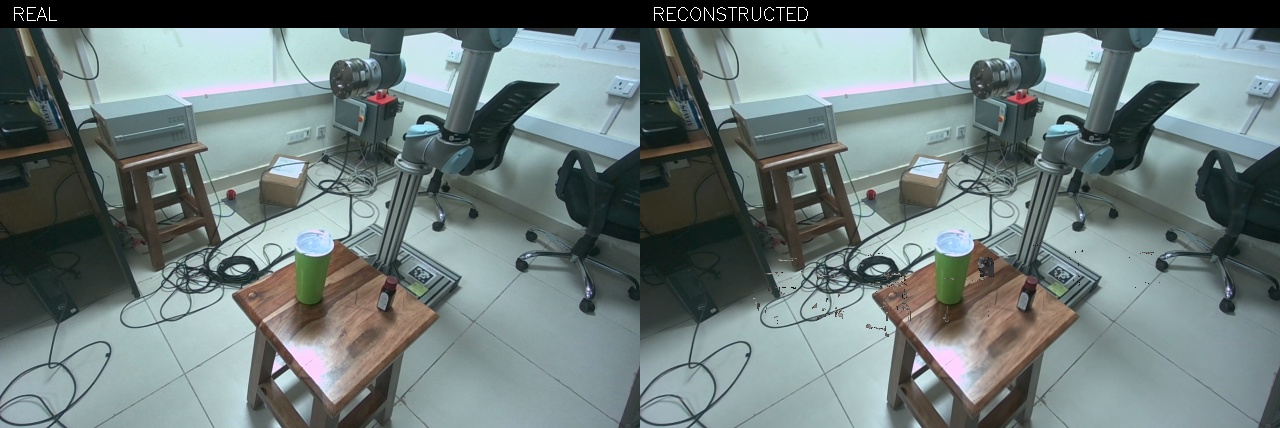
Each capture page compares every method run on that same footage. Numbers are only comparable within a capture.
Interactive
Splat viewer — 34 trained background(s), free-flown in the browser and compared two at a time under one camera. Renders client-side, so it needs no GPU and nothing running on the cluster. Videos below are fixed paths; this is not.
Three-bucket tube sorting
ACT policy export, evaluation videos and reproducibility files.
View the tube-sorting policy → · Tube bin picking: scripted expert evaluation → · Tube bin picking sim2real: progress → · Dense bin picking with scanned objects → · Asset library (1000+ objects, scenes, robots) →